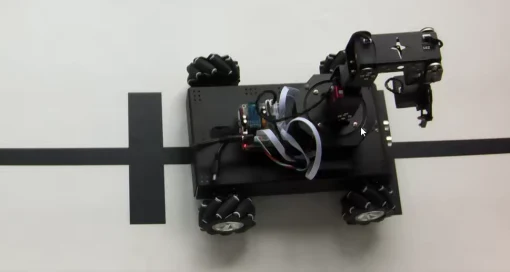
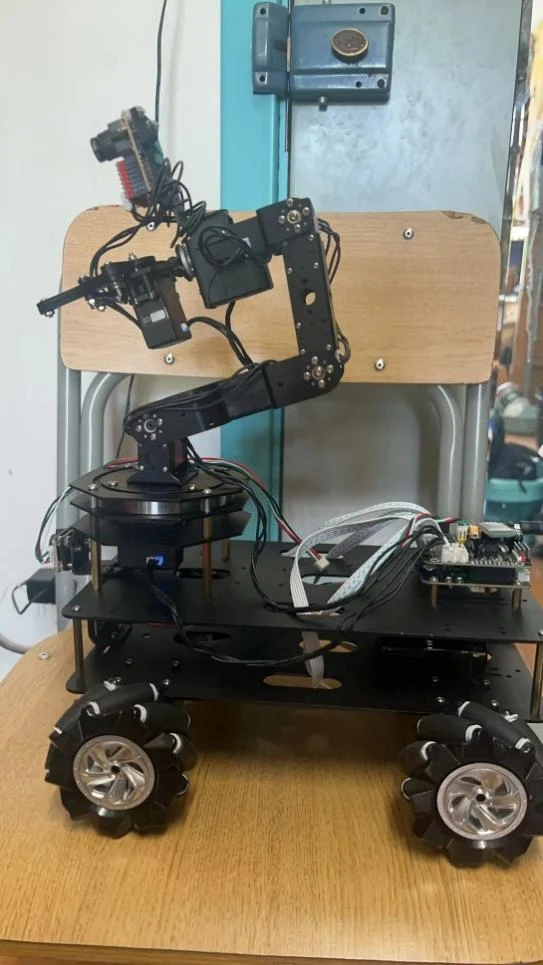
From seeing
to moving.
A study of an STM32-based material-handling robot, bringing mobile movement, visual recognition, and robotic-arm control into one system.
Read the complete report ↗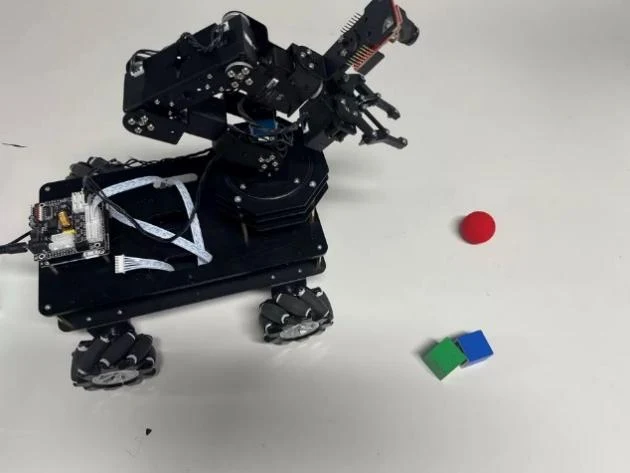
- AUTHOR
- Yuhan (Ash) Wang
- SUPERVISION
- Professor Tian Yin Hong
田应洪 - ORIGINAL REPORT
- 基于STM32的智能搬运机器人设计
Chinese · Word document
One system,
several languages.
A material-handling robot connects several kinds of reasoning: the mechanics of the mobile platform, electrical interfaces, perception from a camera, and mathematical descriptions of an arm's motion. The report follows these parts from system selection through control methods and experimental testing.
Move reliably.
An STM32F407VET6 controller, motors, sensors, and PID control support the mobile platform. The report also examines line following and obstacle avoidance.
Recognize a target.
An OpenMV vision module provides a path from image features to material recognition and visual control.
Reach and grasp.
Forward and inverse kinematics, Jacobian analysis, and trajectory planning describe how the arm can move toward a target.
Study, test,
then refine.
The experimental sections document arm-offset adjustments, visual material handling, and grasping tests. The report ends by considering remaining limitations and directions for improvement.